What is a User Coordinate System in Yaskawa robots?
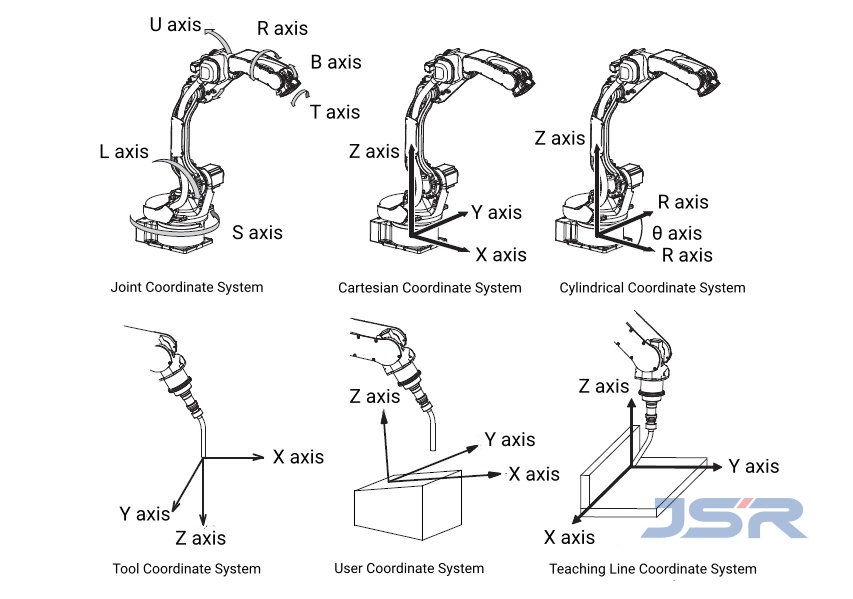
It is a customized XYZ Cartesian coordinate system defined by the user at any position and angle within the robot’s working area. Once calibrated, the robot’s TCP moves parallel to its X, Y, and Z axis.
What coordinate systems are available on Yaskawa robots?
Joint, Cartesian, Cylindrical, Tool, User, and Tool Jog coordinate systems.
Post time: Nov-02-2026